Archive

biped
2024
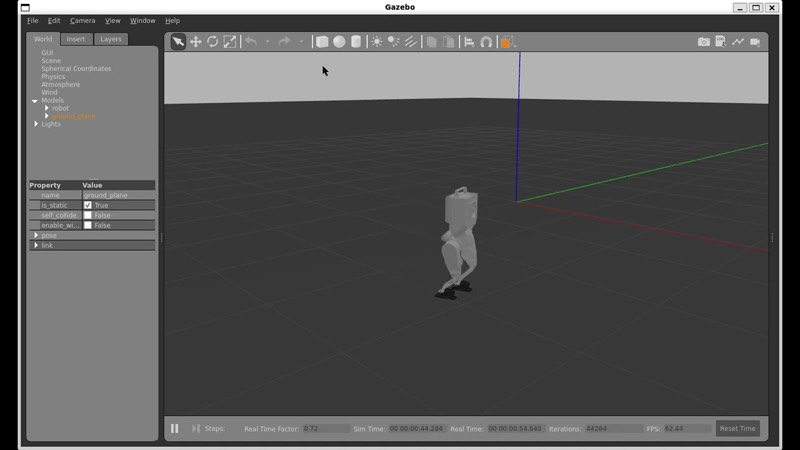
Bipedal robot walking with geometric MPC
Geometric Variation-Based MPC for a Bipedal Robot
UC Berkeley. A coordinate-free geometric model, linearized by variation so the discretized system conserves energy, enables stable walking with convex MPC.
wheeled biped
2023
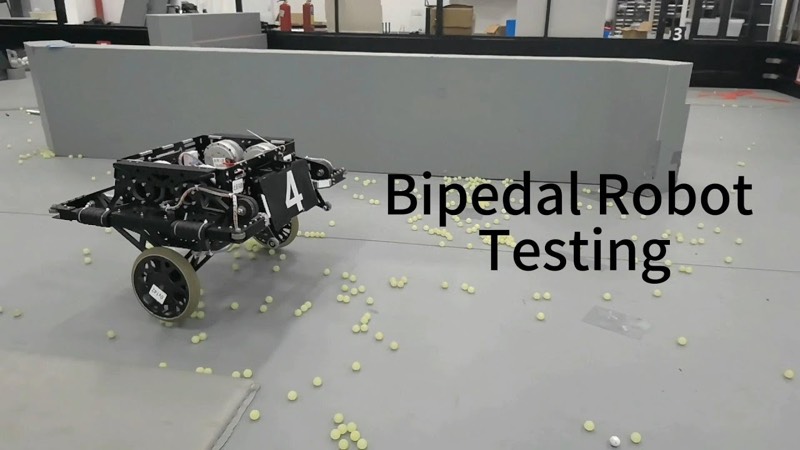
Wheeled-bipedal robot
State Estimation and Control of a Wheeled-Bipedal Robot
USTC RoboMaster Team. Slip detection from wheel contact-point velocities and an LQR controller built on whole-body dynamics.
navigation
2023
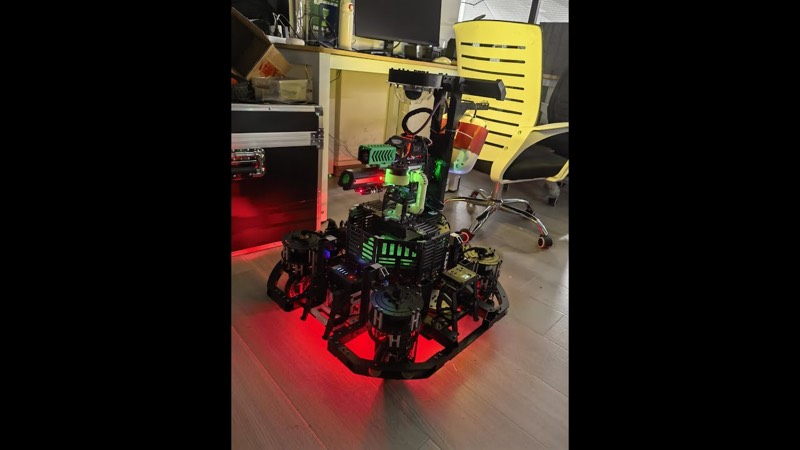
Omnidirectional robot navigating uneven terrain
SLAM and Navigation of an Omnidirectional Robot
USTC RoboMaster Team. Lidar, IMU, and encoder fusion with a Kalman filter for localization, plus point-cloud segmentation to judge terrain traversability.